OUR TECHNOLOGY

Active inference

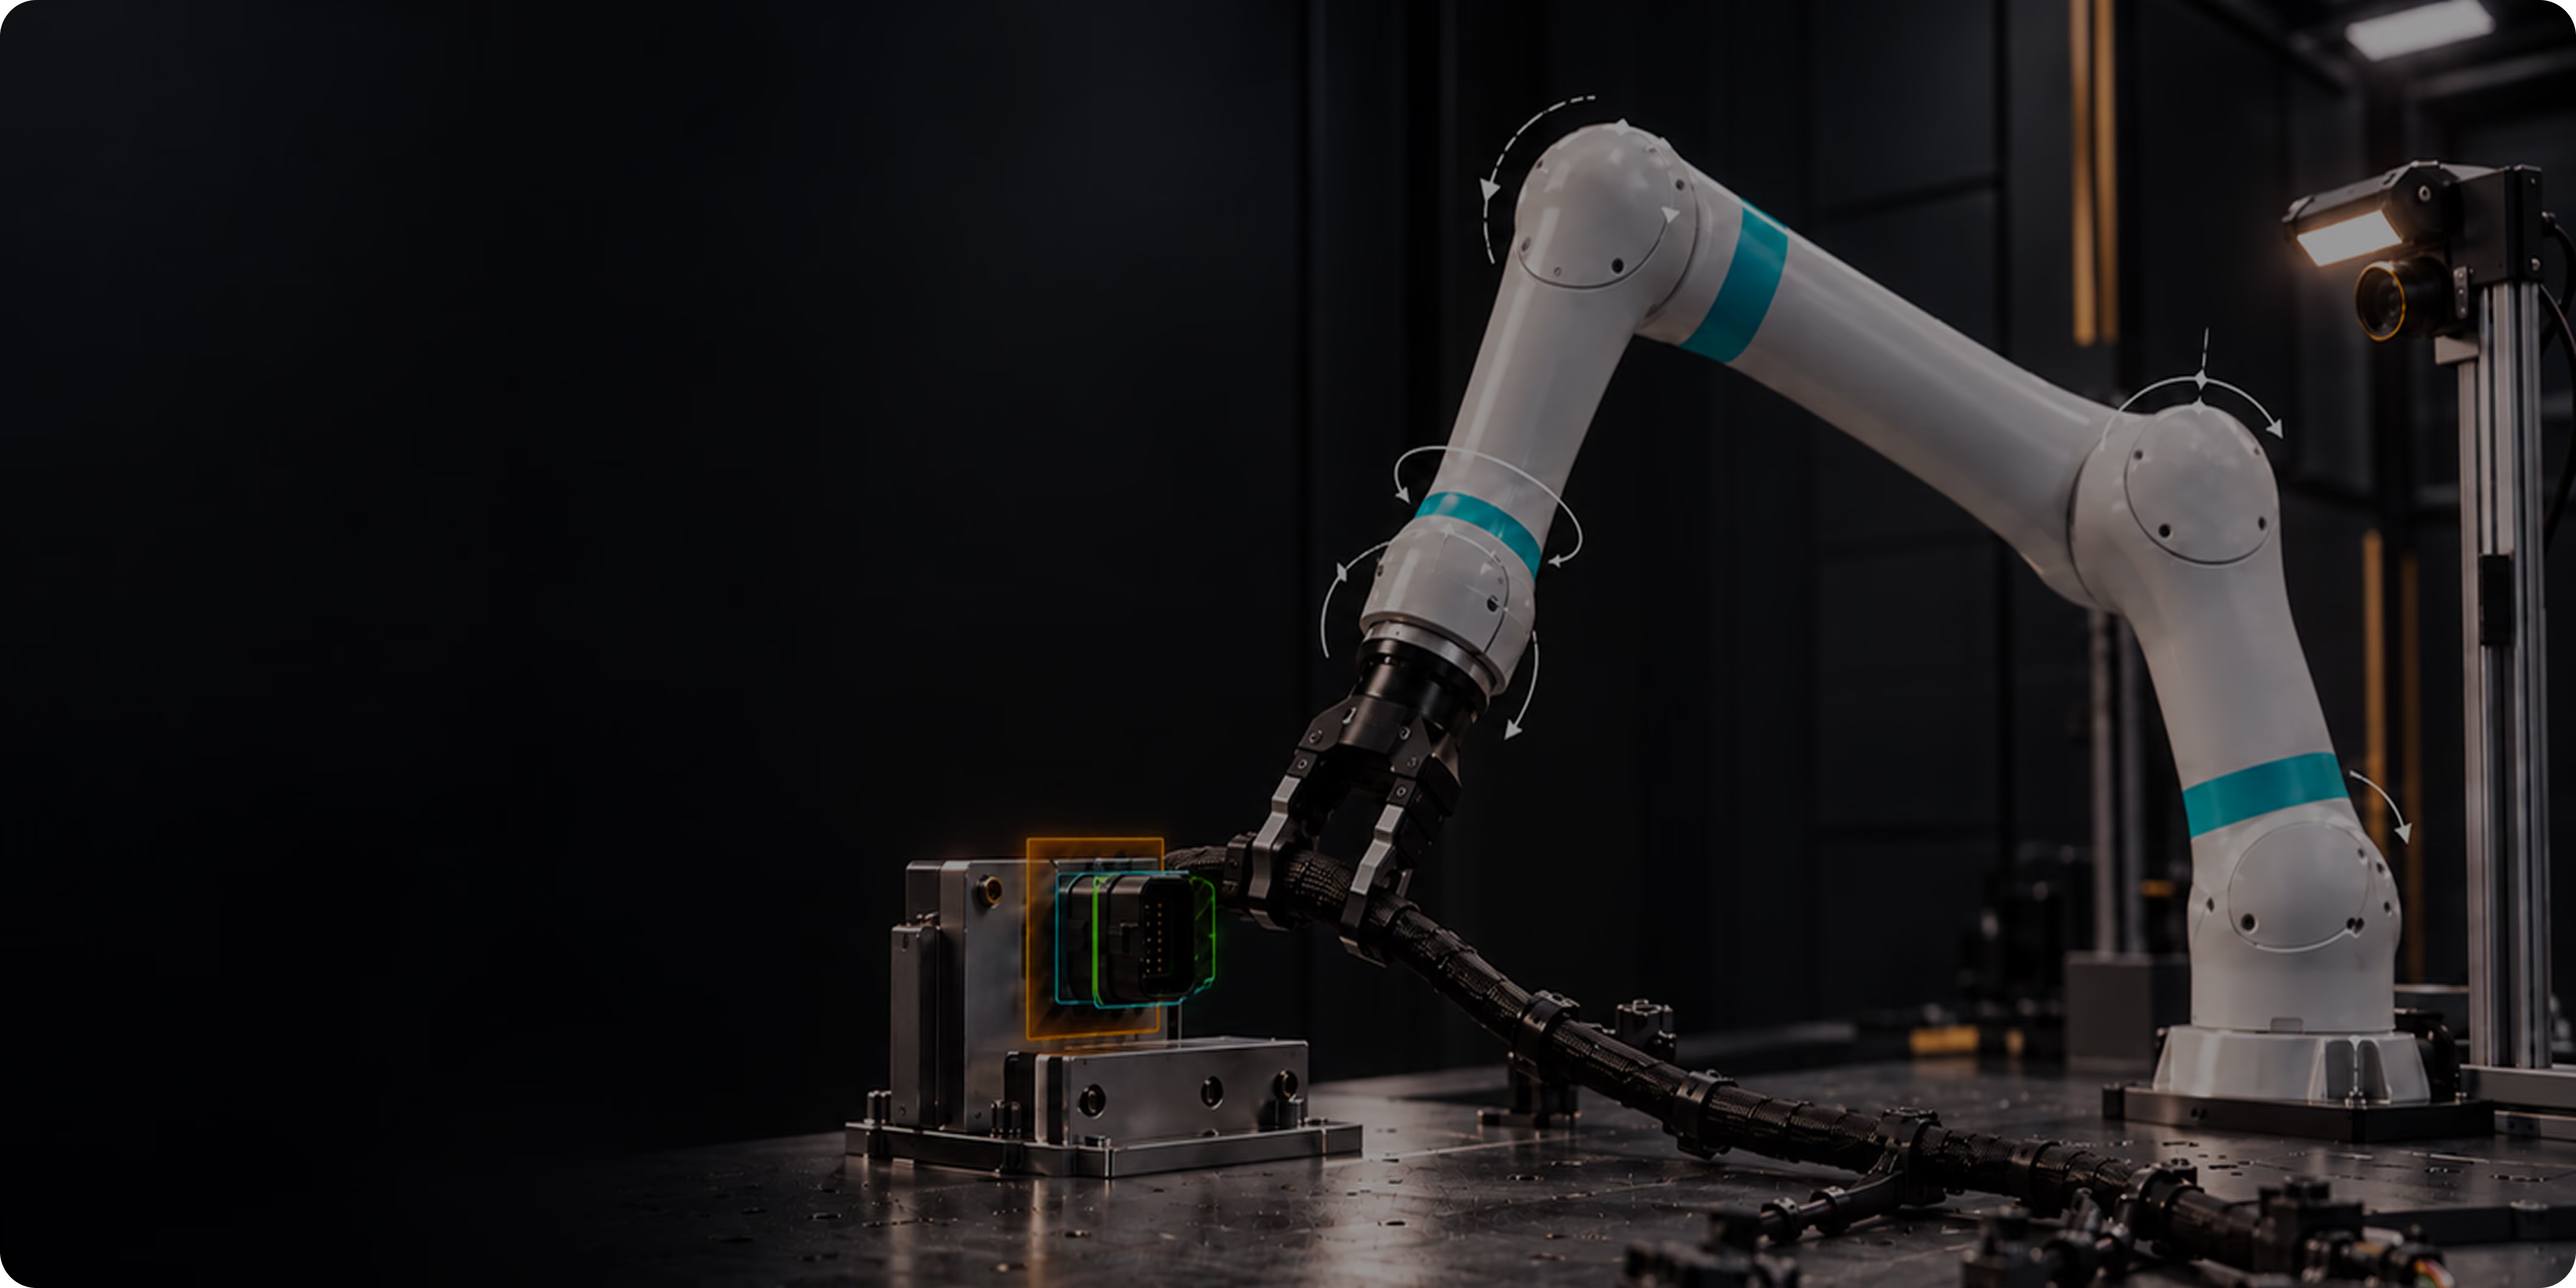
The model predicts what its sensors register, then adapts to the difference. Sensing, Adapting, and Acting are the same computation.
Programs and partners

What it does

The hard part

01

Generalizable Model

One model that works across multiple scenarios.

02

Confidence Driven

Models are intrinsically motivated to minimize both surprise and uncertainty.

03

Goal Driven

Outcomes encoded as probability distributions in the model.

04

Edge based

Up to 1 kHz on local compute. No cloud in the control path, nothing leaving the site.
“The technology that underwrites ThoughtForge is beautifully simple and almost magically powerful. Its power is inherited from a deep commitment to first principles — originating in cybernetics — and evincing the fundamentals of self-organisation: by engineering fast, free energy minimising dynamics in silico, ThoughtForge can create artefacts that respond optimally in the blink of an eye. This remarkable capacity rests on exploring configuration spaces dynamically within milliseconds. It is a fundamentally different approach – to context-sensitive, optimal behaviour — that opens up new avenues in control theory and a myriad of applications."
Karl Friston, Inventor of the Field of Active Inference.

Explore our Technology in Action: Case Studies

Connector Mating

A single control model picked, aligned, and mated two dissimilar connector families with zero per-connector programming and zero reconfiguration to switch between connector types.

Thank you! Your submission has been received!
Oops! Something went wrong while submitting the form.

Adaptive Insertion

A ThoughtForge controlled robotic arm autonomously inserted deformable and rigid automotive parts into their housings in unpredictable, real world conditions with an insertion reliability of 95%.

Thank you! Your submission has been received!
Oops! Something went wrong while submitting the form.

Wire Harness

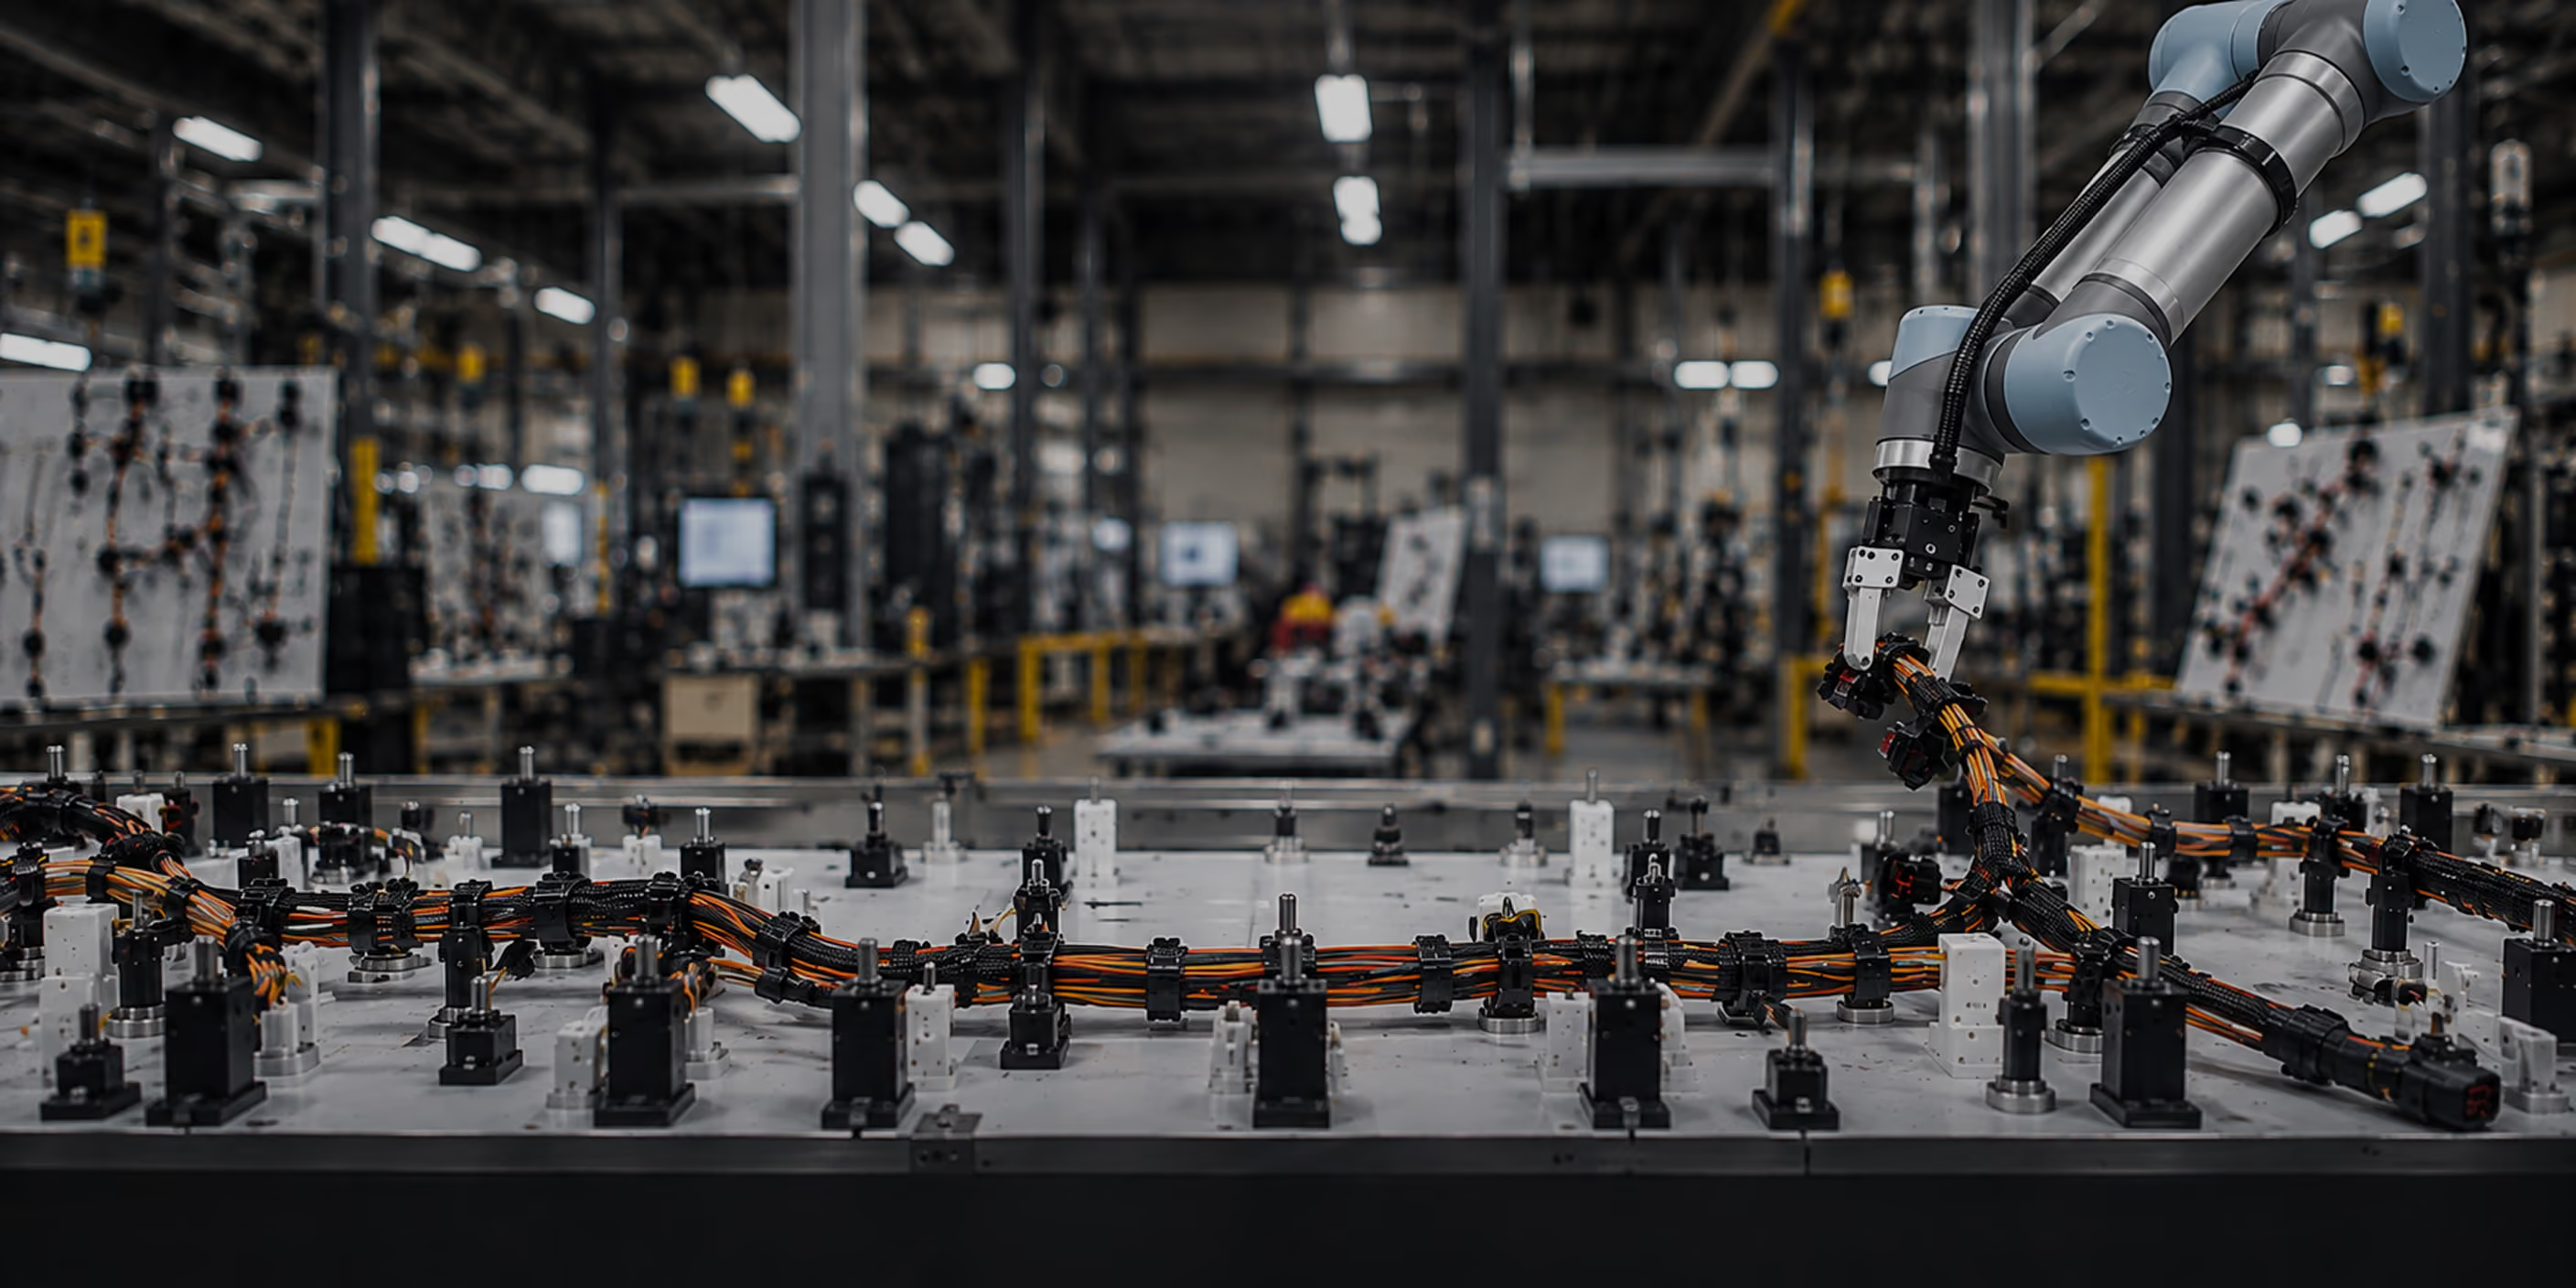
Wire harness automation does not fail on any one case. It fails on the long tail: each exception is solvable, but innumerable, and the engineering cost never amortises.

Thank you! Your submission has been received!
Oops! Something went wrong while submitting the form.

Valve Manipulation

BP wanted a robotic arm that could reliably manipulate a variety of valves with no prior knowledge of each valve: no CAD model, no measured geometry, no knowledge of its physical properties.

Thank you! Your submission has been received!
Oops! Something went wrong while submitting the form.

Adaptive Robotic Insertion

A single model handles many parts: rather than training and tuning a separate model for every part number, one controller adapts to whatever part it is given.

Thank you! Your submission has been received!
Oops! Something went wrong while submitting the form.
NEXT STEPS

Ready to automate your dexterous tasks?

Book a Demo