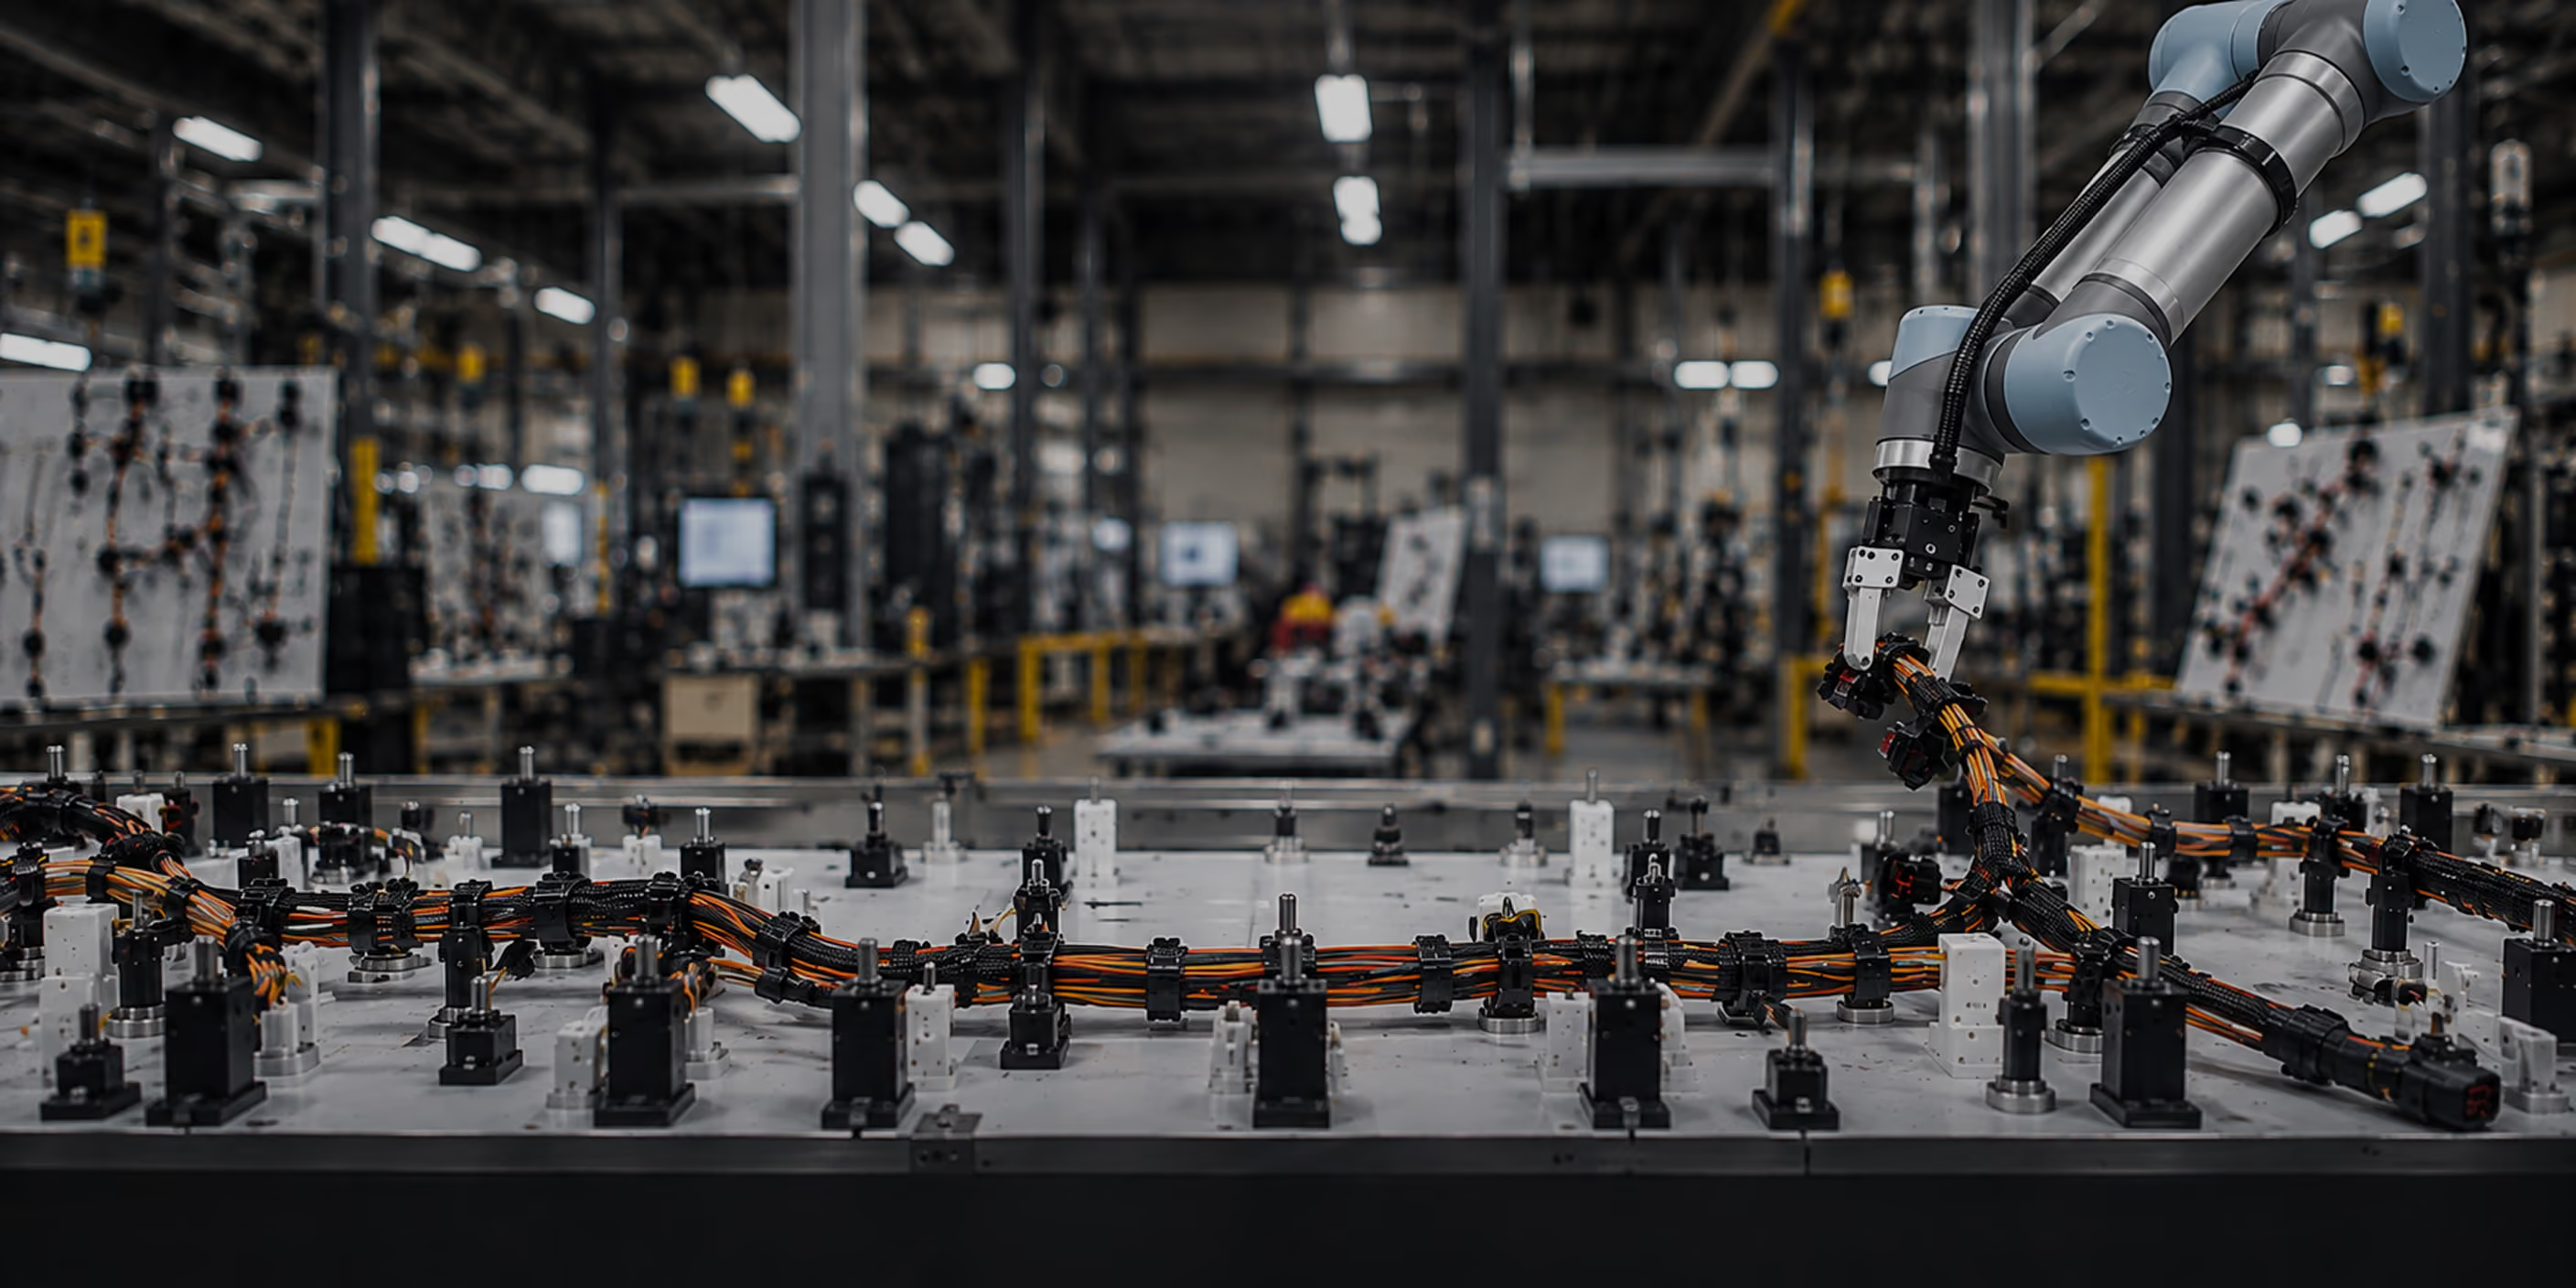
Dexterous AI for Contact Rich Robotic Work
Robotic control for physical work that resists automation. Parts that flex, move and change when touched. No two tasks or units are the same.
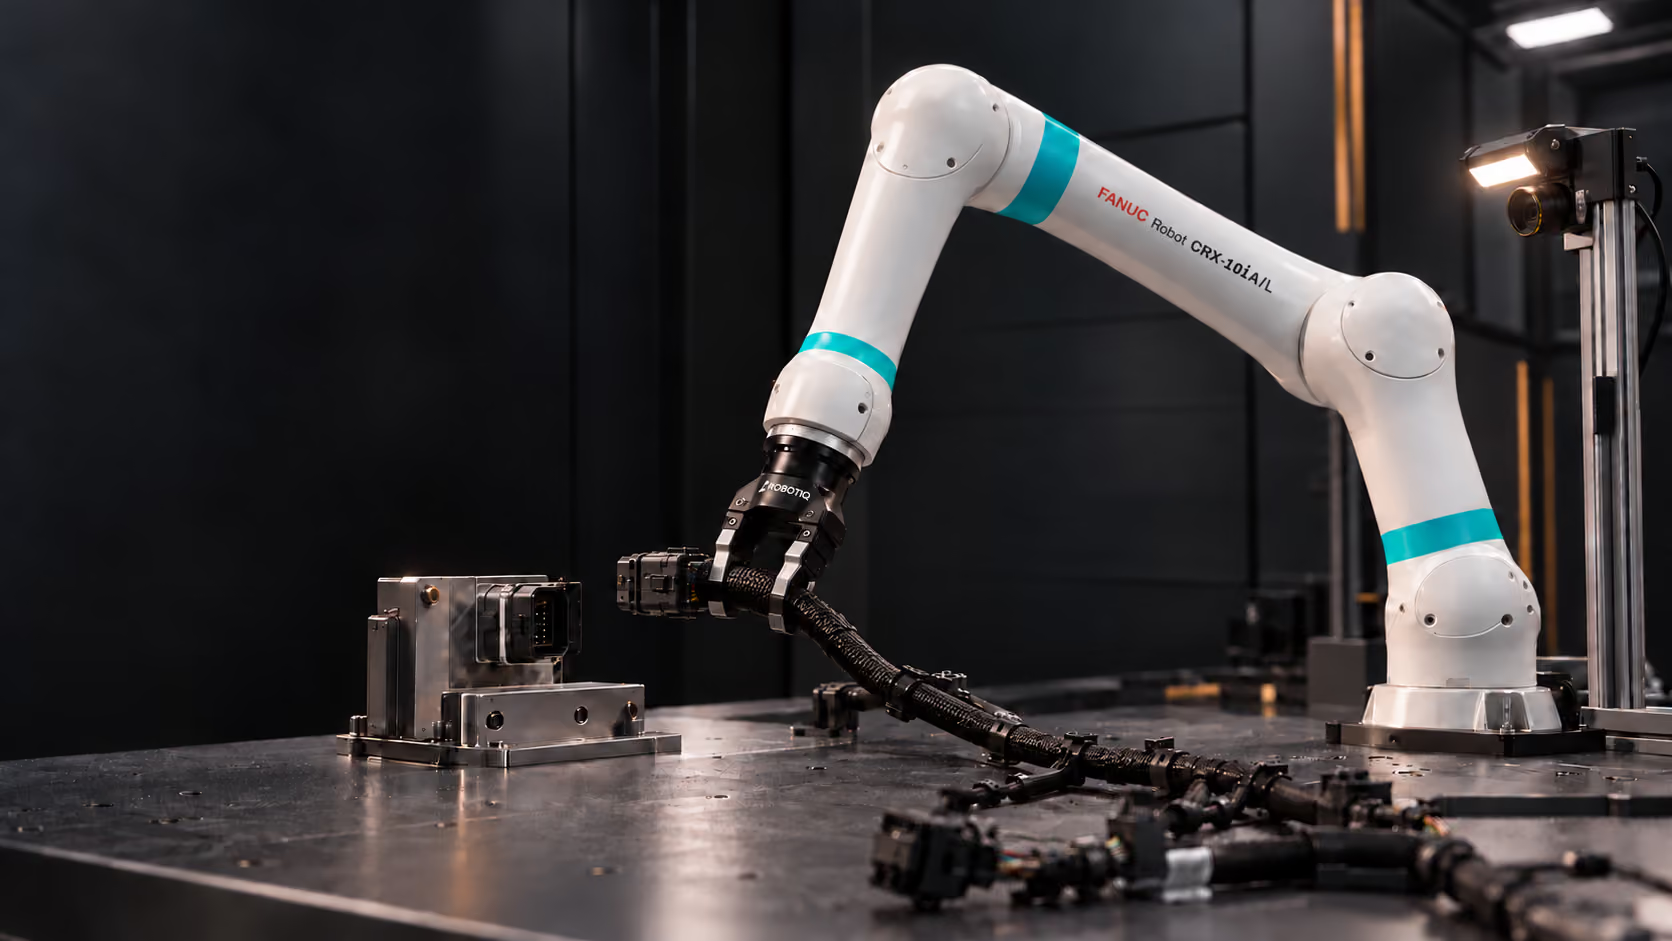


One model. Multiple skills.
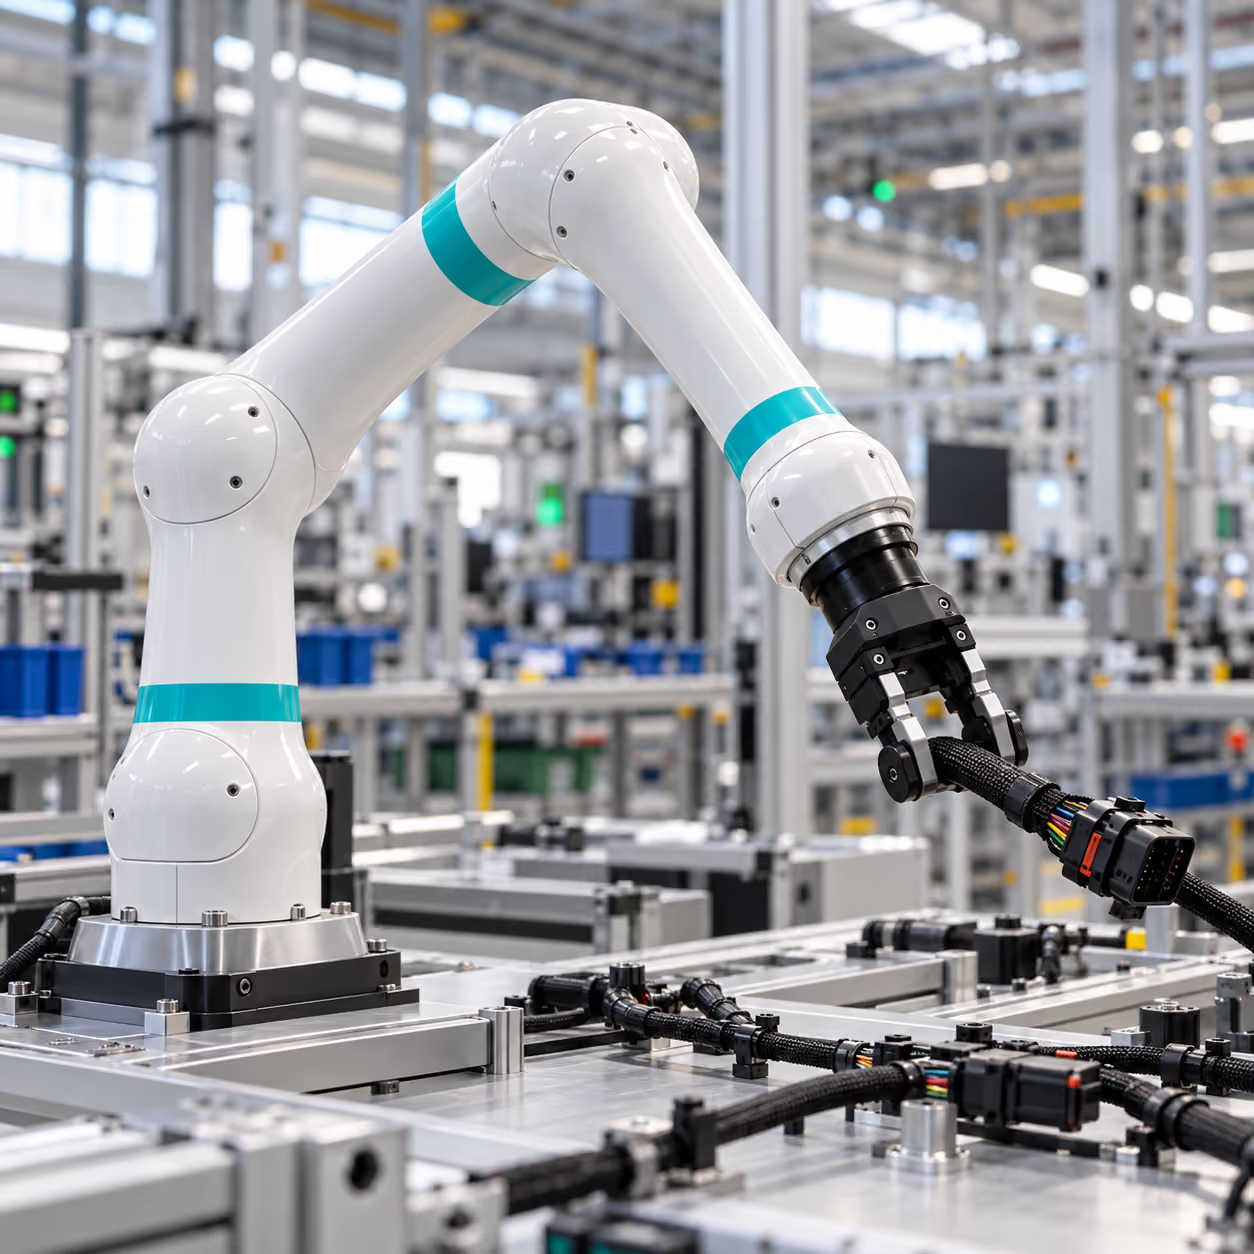
5,6 and 7 Degree of Freedom Arms
A new arm is a calibration pass, not a reprogramming job.
Three industries, one model
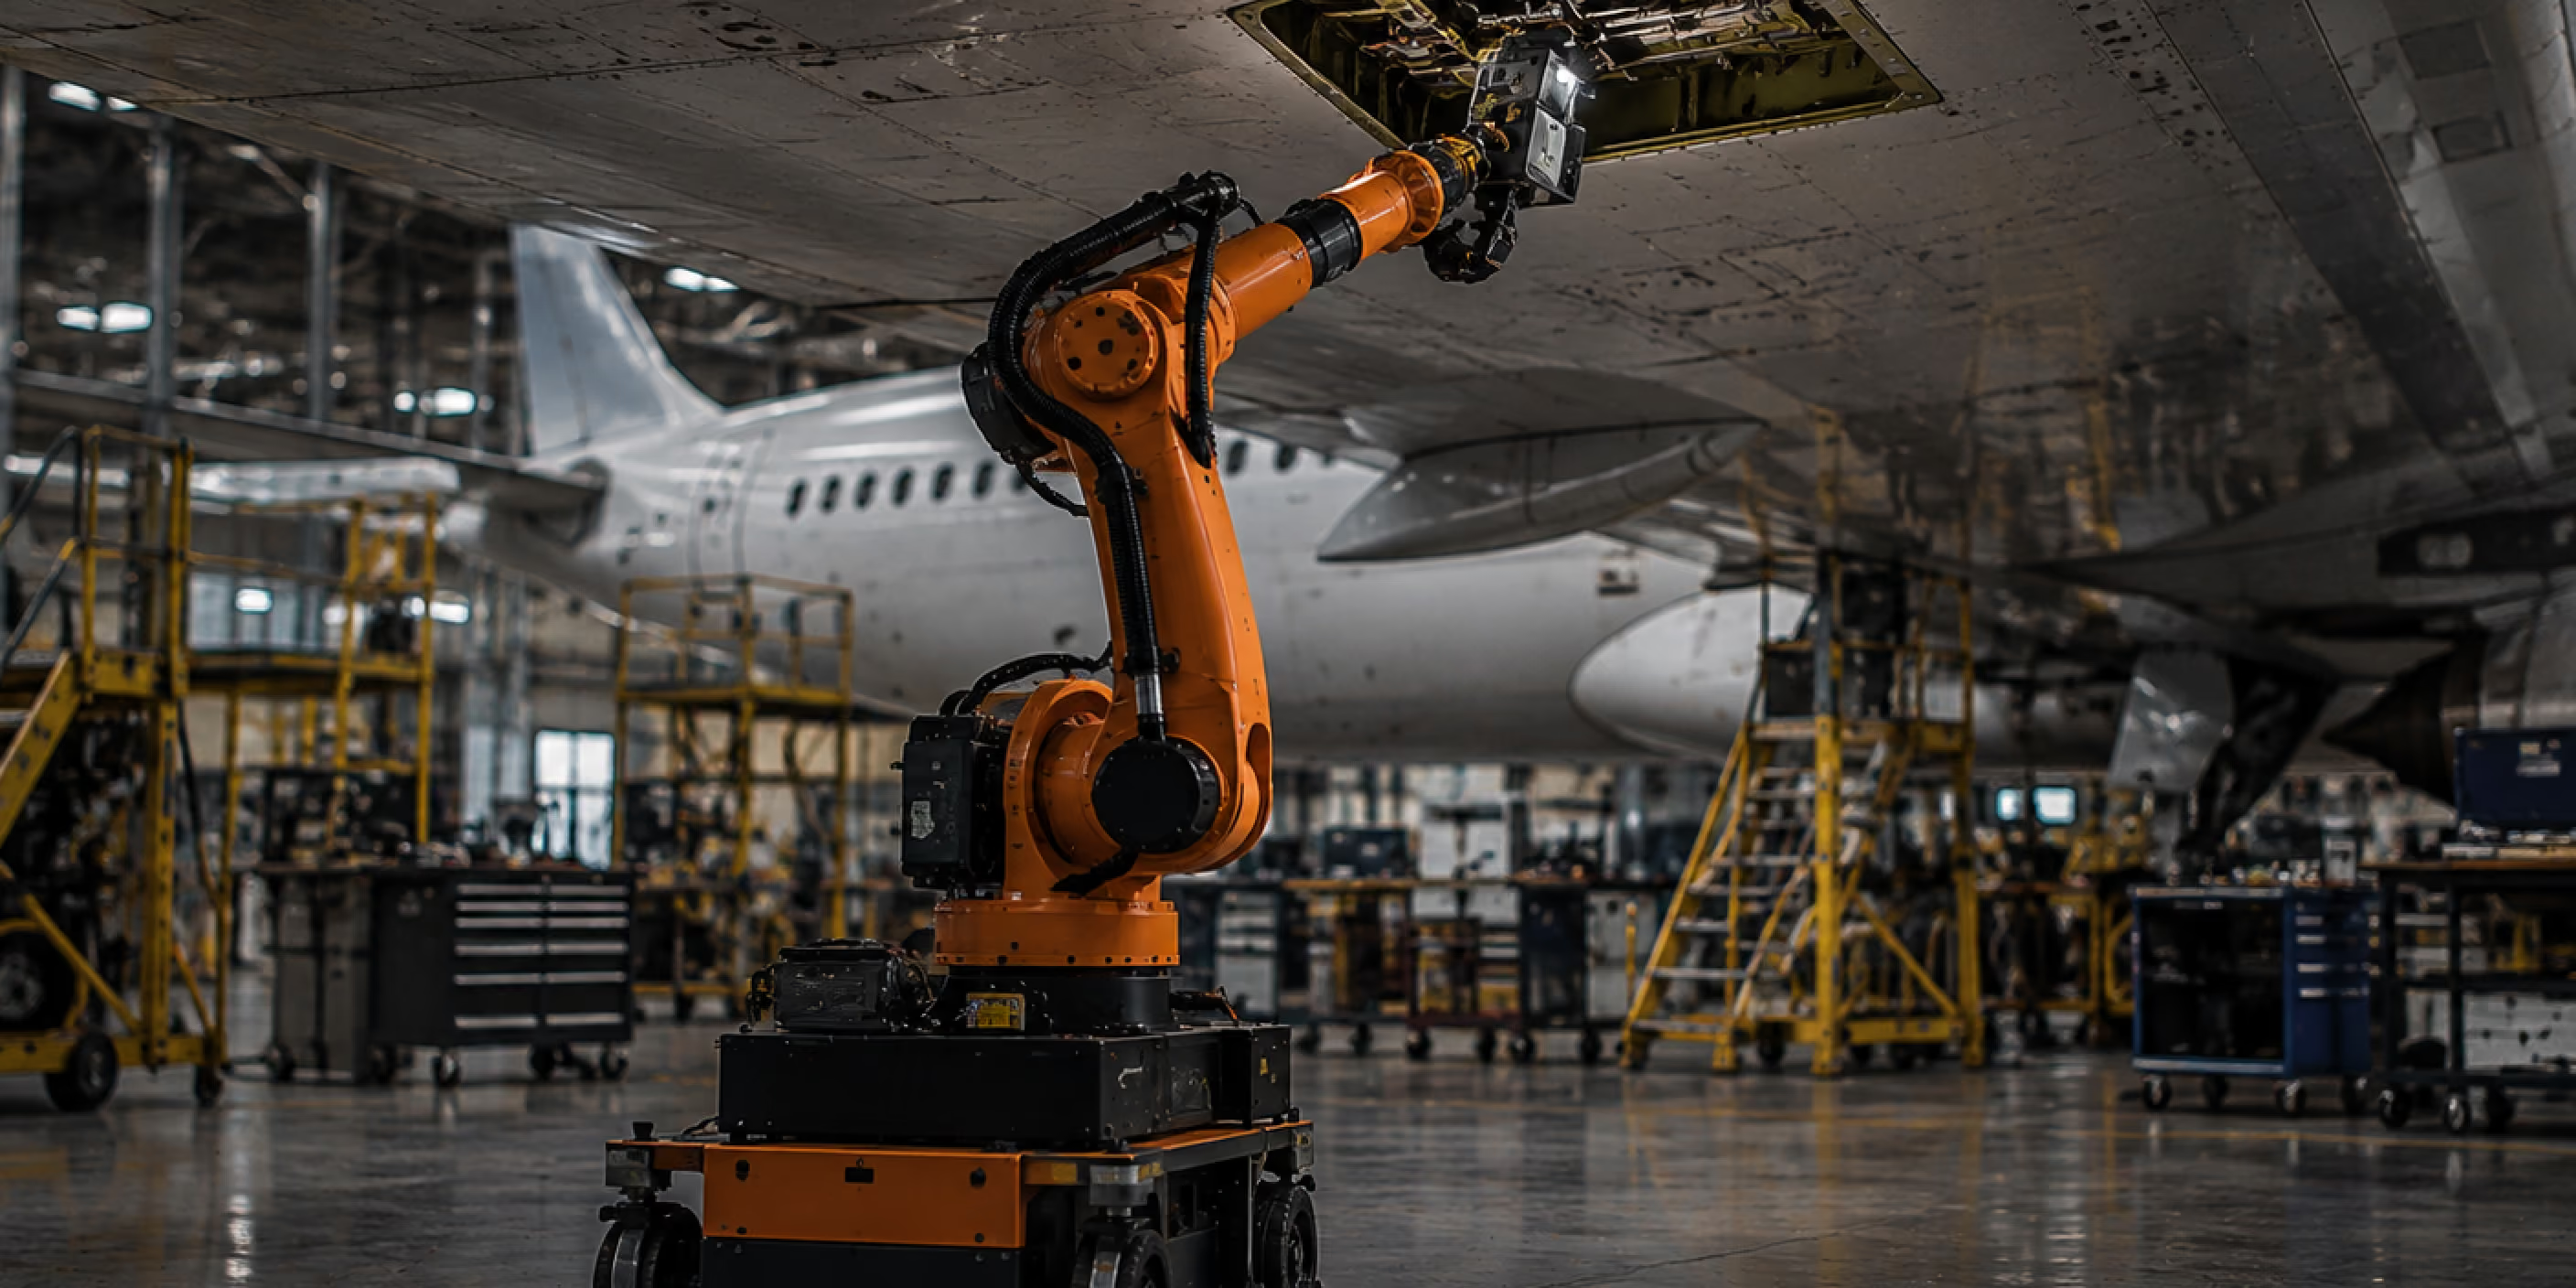
Inspections
Confined spaces, fuel tanks, ducts, wings, fuselage.
Object Manipulation
Complex tubing, pipes, valves, deformable and rigid objects.
Insertion and Mating
Threading, clip insertion, connector orientation and mating, including blind mating.
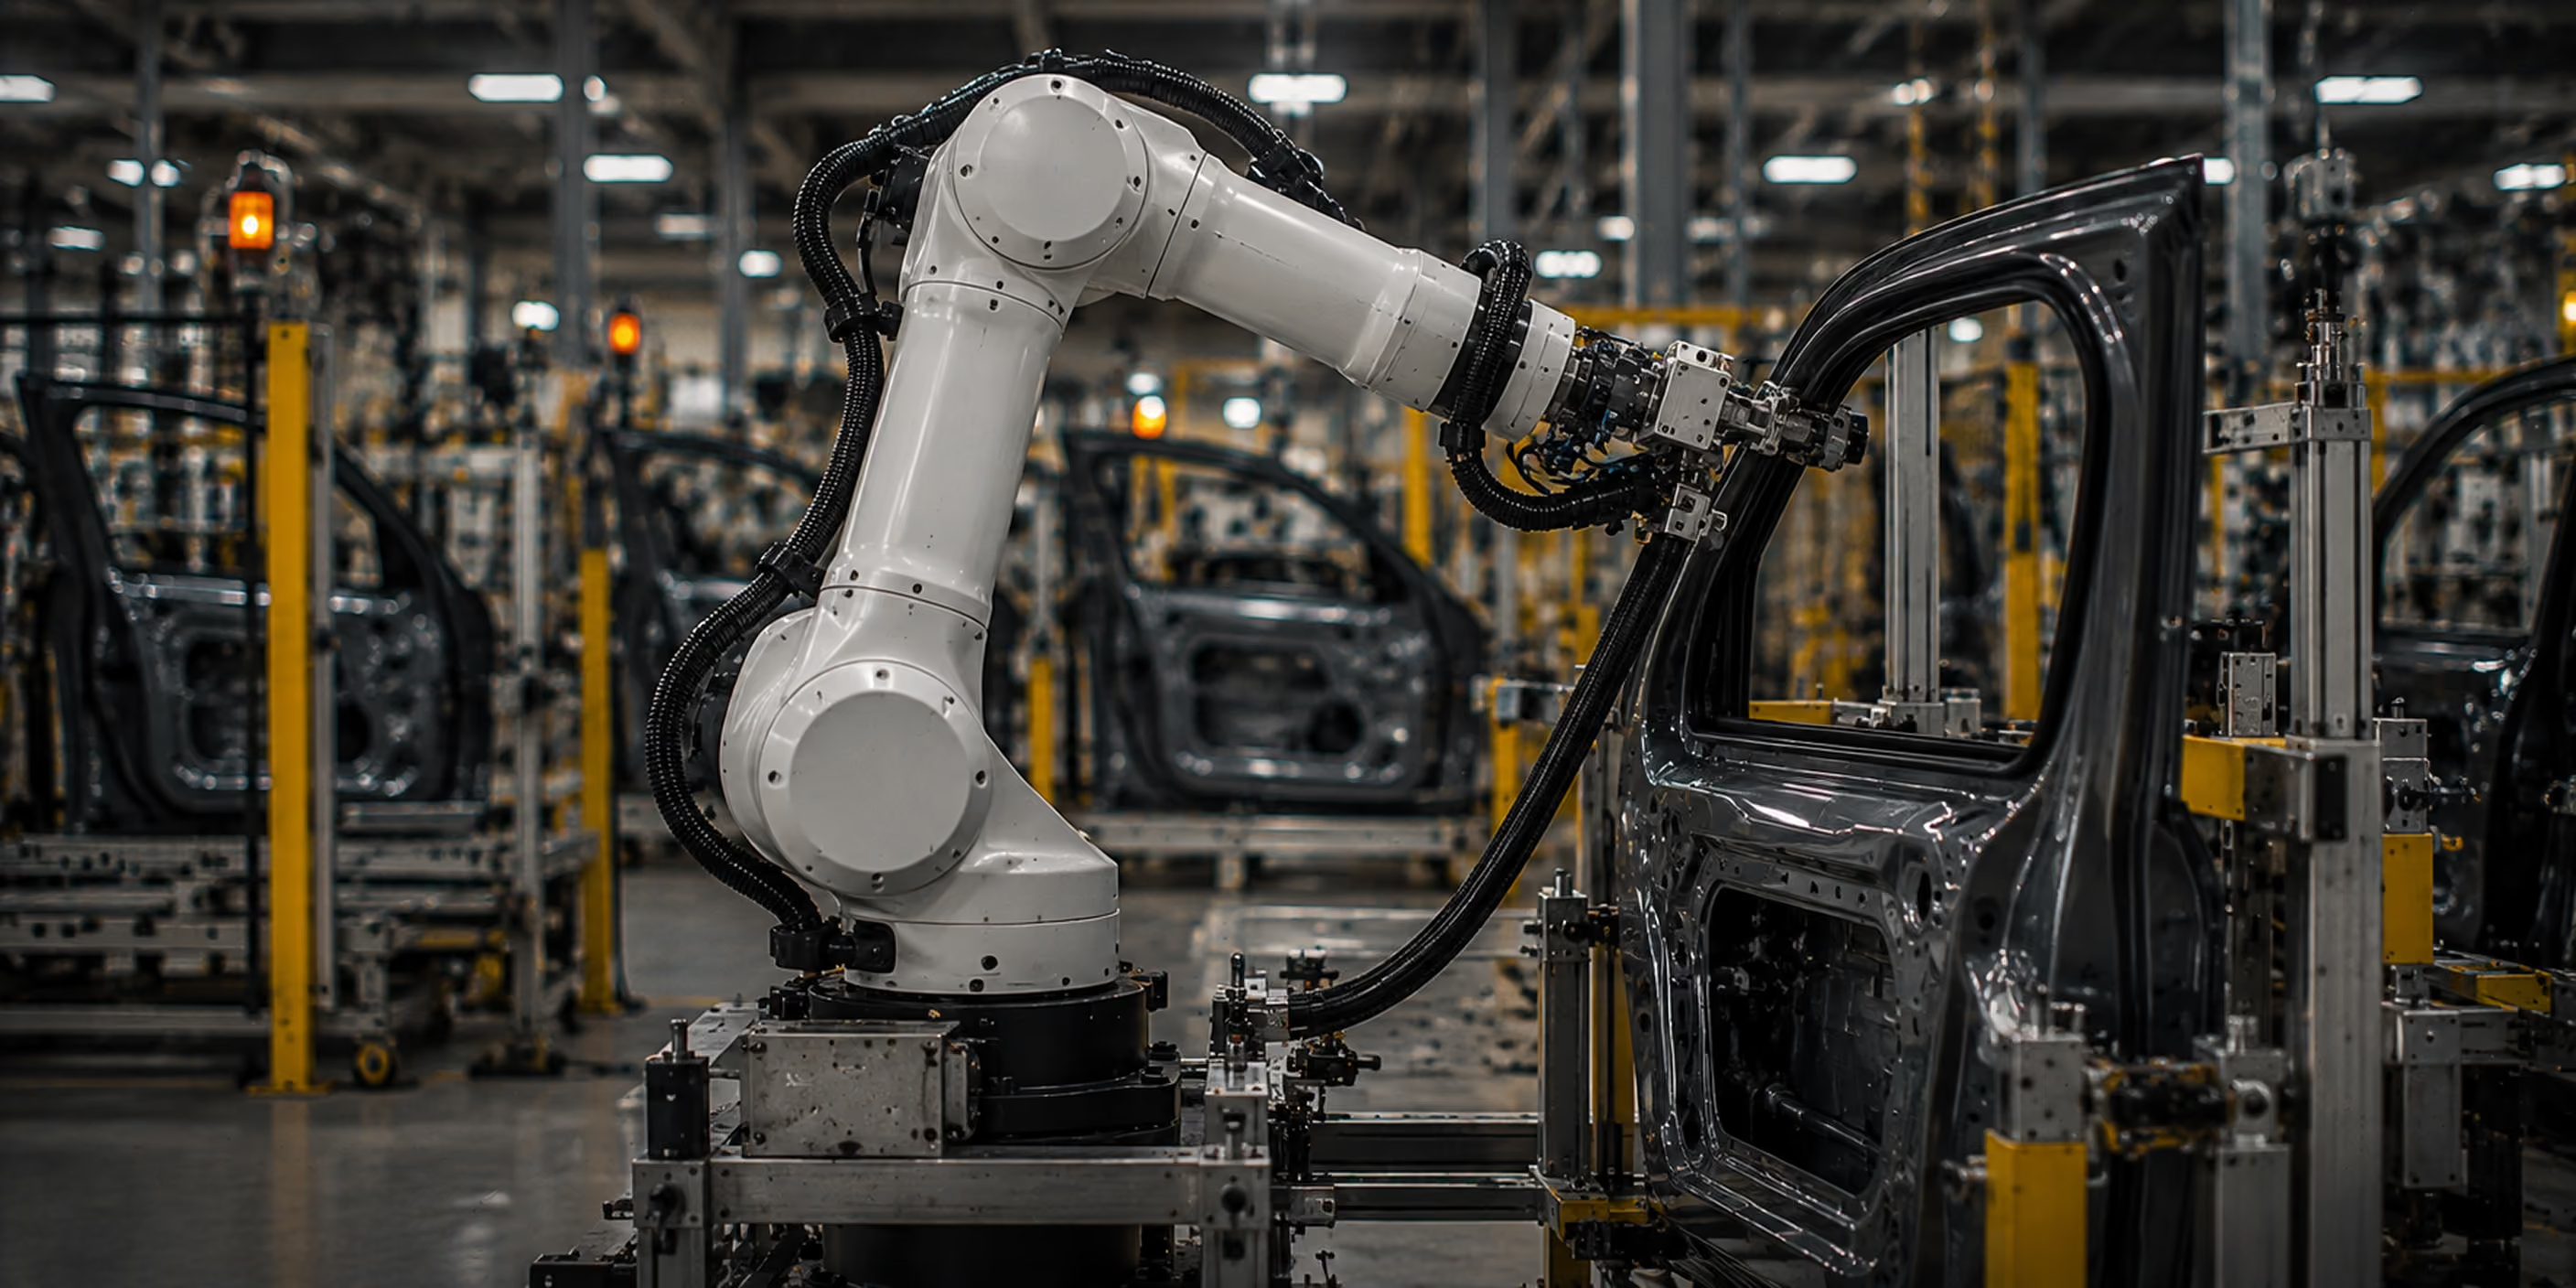
Object Manipulation
Weather stripping, door gasket, door silencers, threshold, sweep, and other rubber parts, deformable and rigid objects.
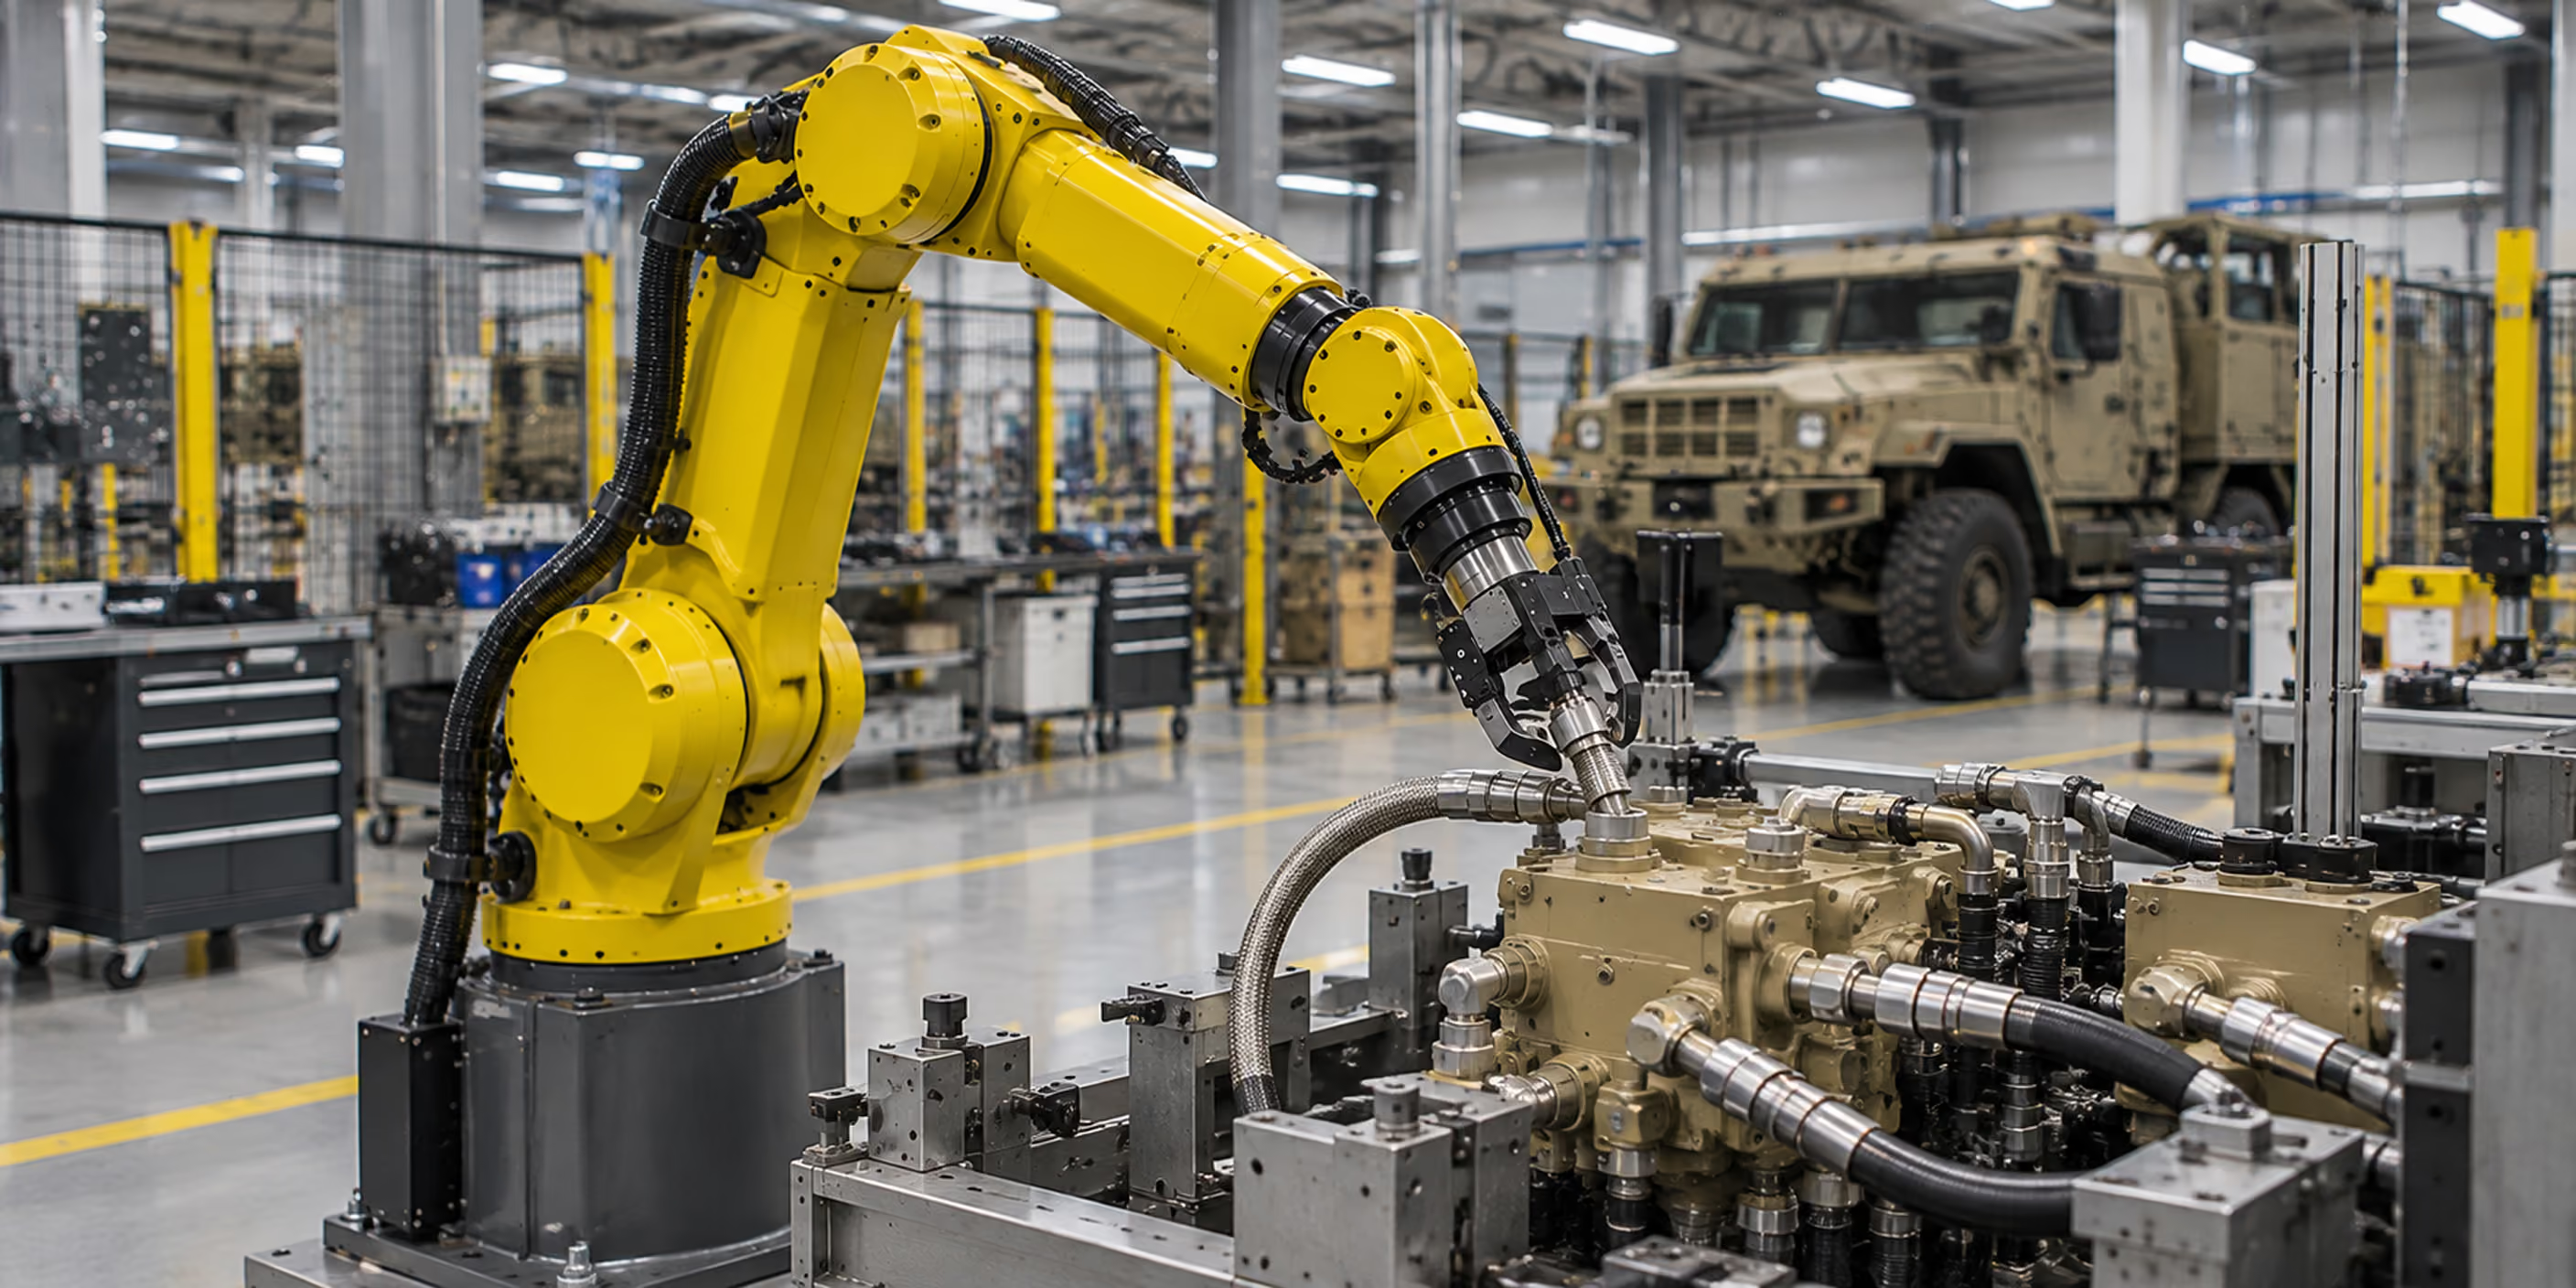
Insertion and Mating
Threading, clip insertion, connector orientation and mating, including blind mating.
Inspections
Confined spaces, fuel tanks, ducts, wings, fuselage.
Object Manipulation
Complex tubing, pipes, valves, deformable and rigid objects.
Insertion and Mating
Threading, clip insertion, connector orientation and mating, including blind mating.
Dexterous Robotic Control
The DOD is very excited about this kind of technology (ThoughtForge). DOD manufacturing is typically high mix, low volume, and high variability, which has not been conducive to robotics for the last several decades. This kind of technology is going to enable technology to adapt and be very agile in that environment and, we’re hoping, will revolutionize defense production.
Sr Technical Advisor to the DoD for Aerospace Manufacturing, US Air Force Research Laboratory Government Chief Technical Advisor for The Advanced Robotics Manufacturing Institute