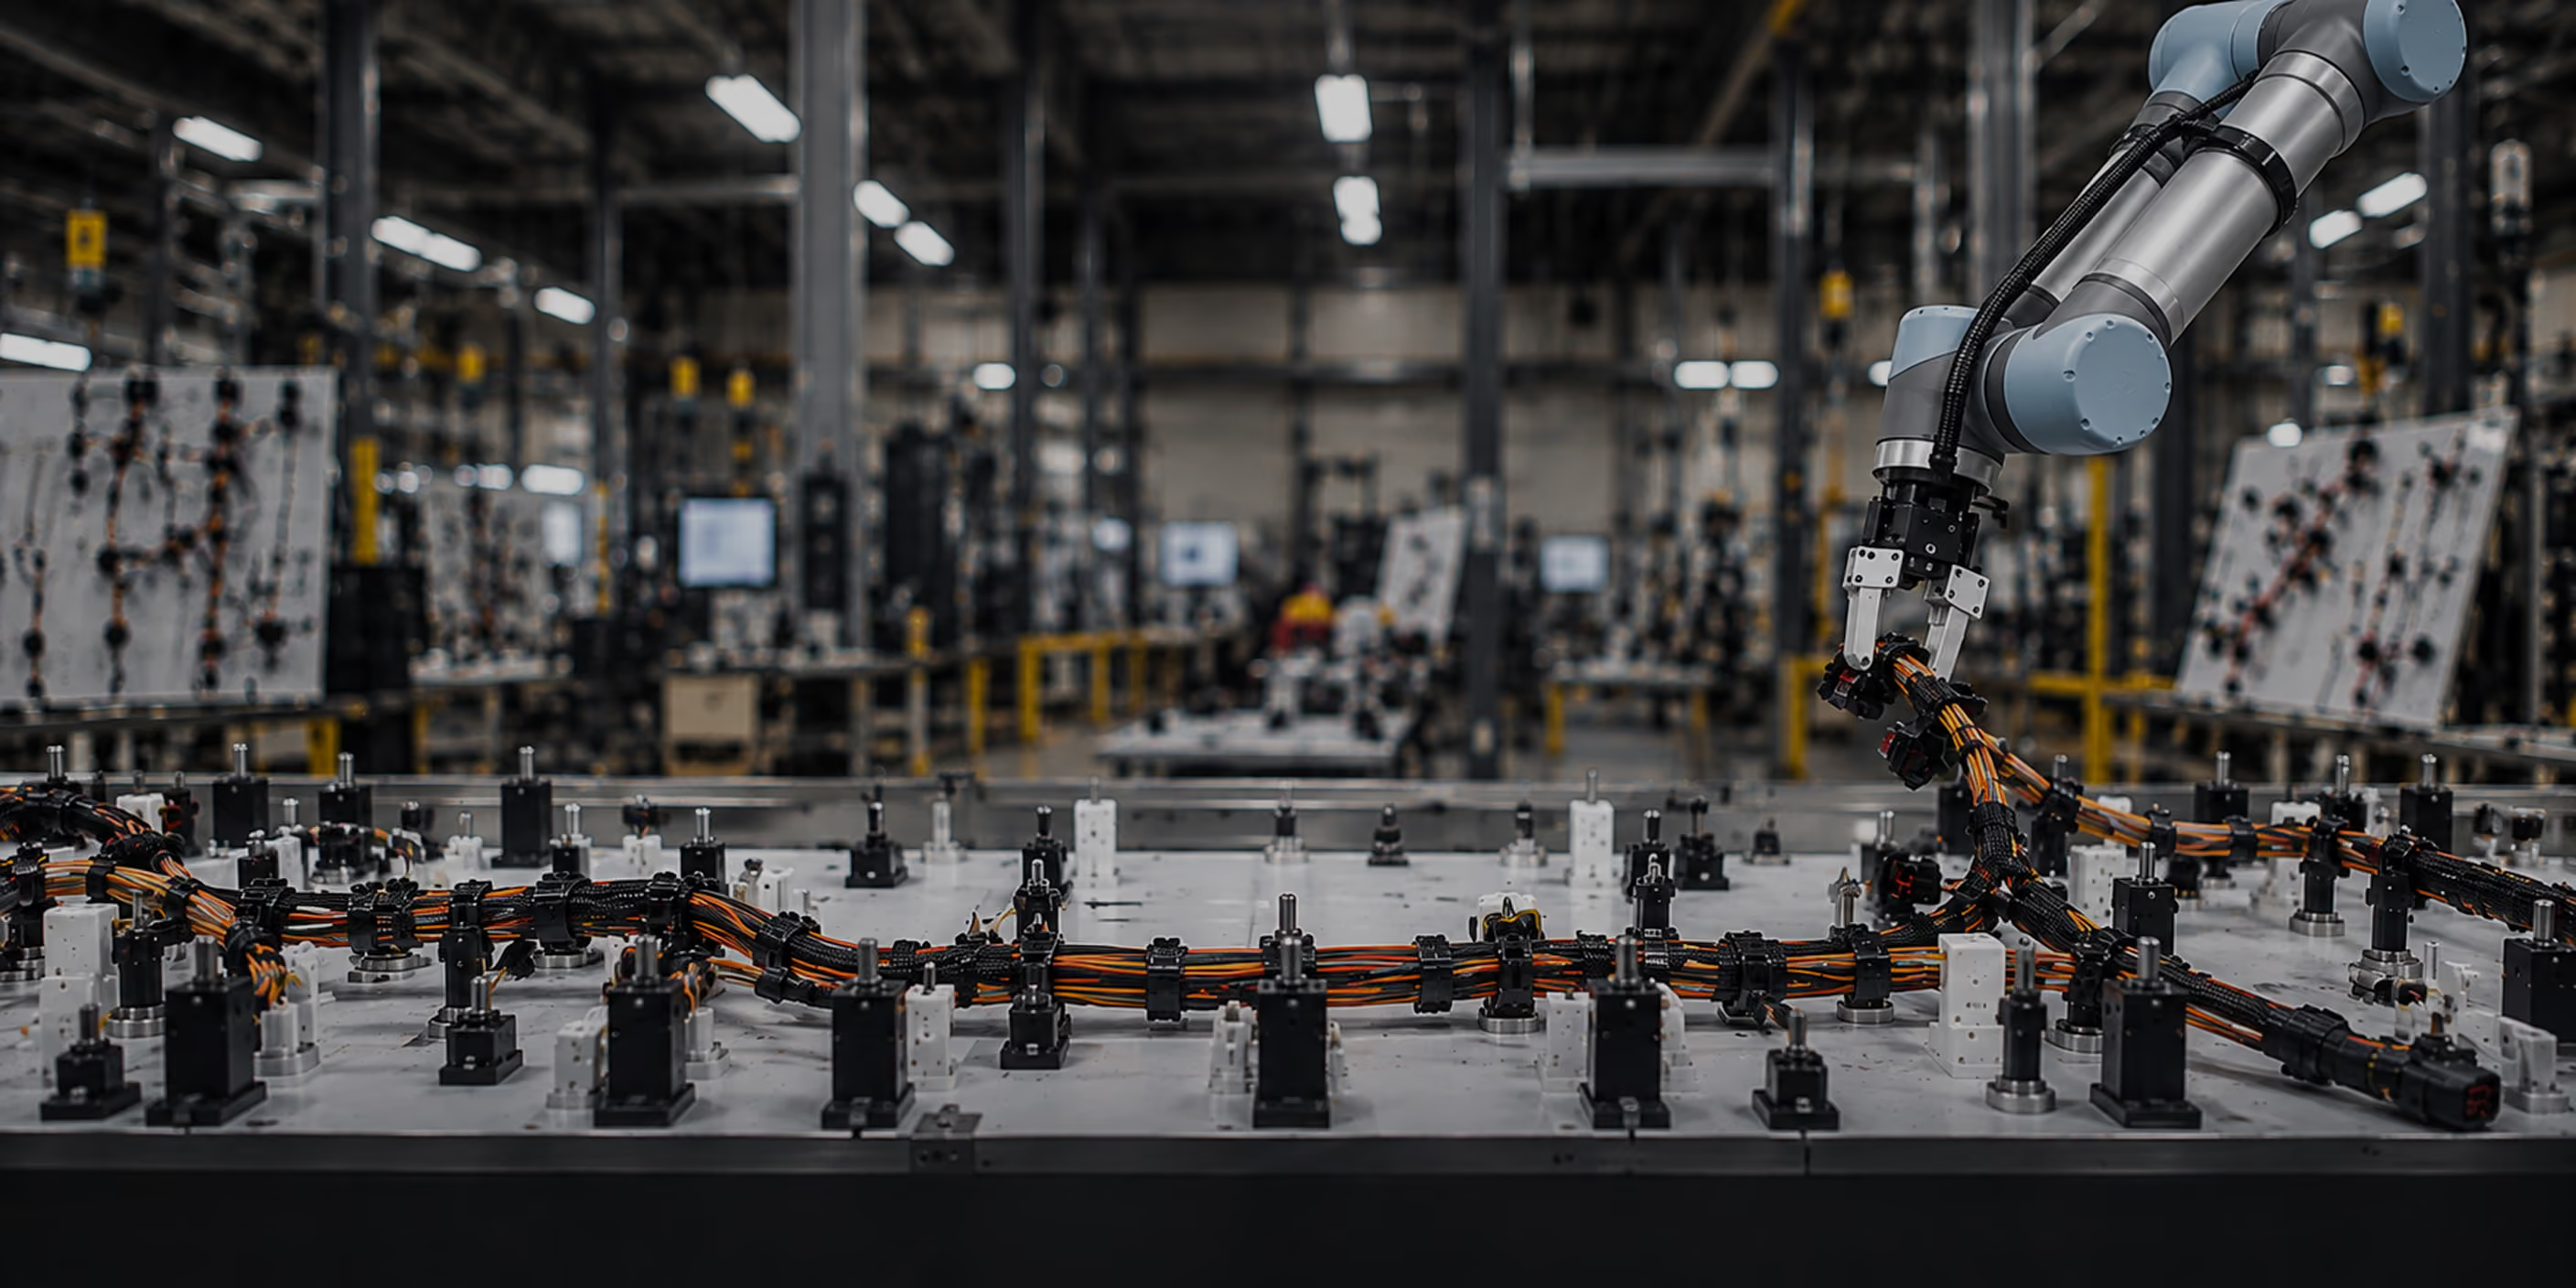
Deformable Object Manipulation
Handle a part that changes shape as you grip it.
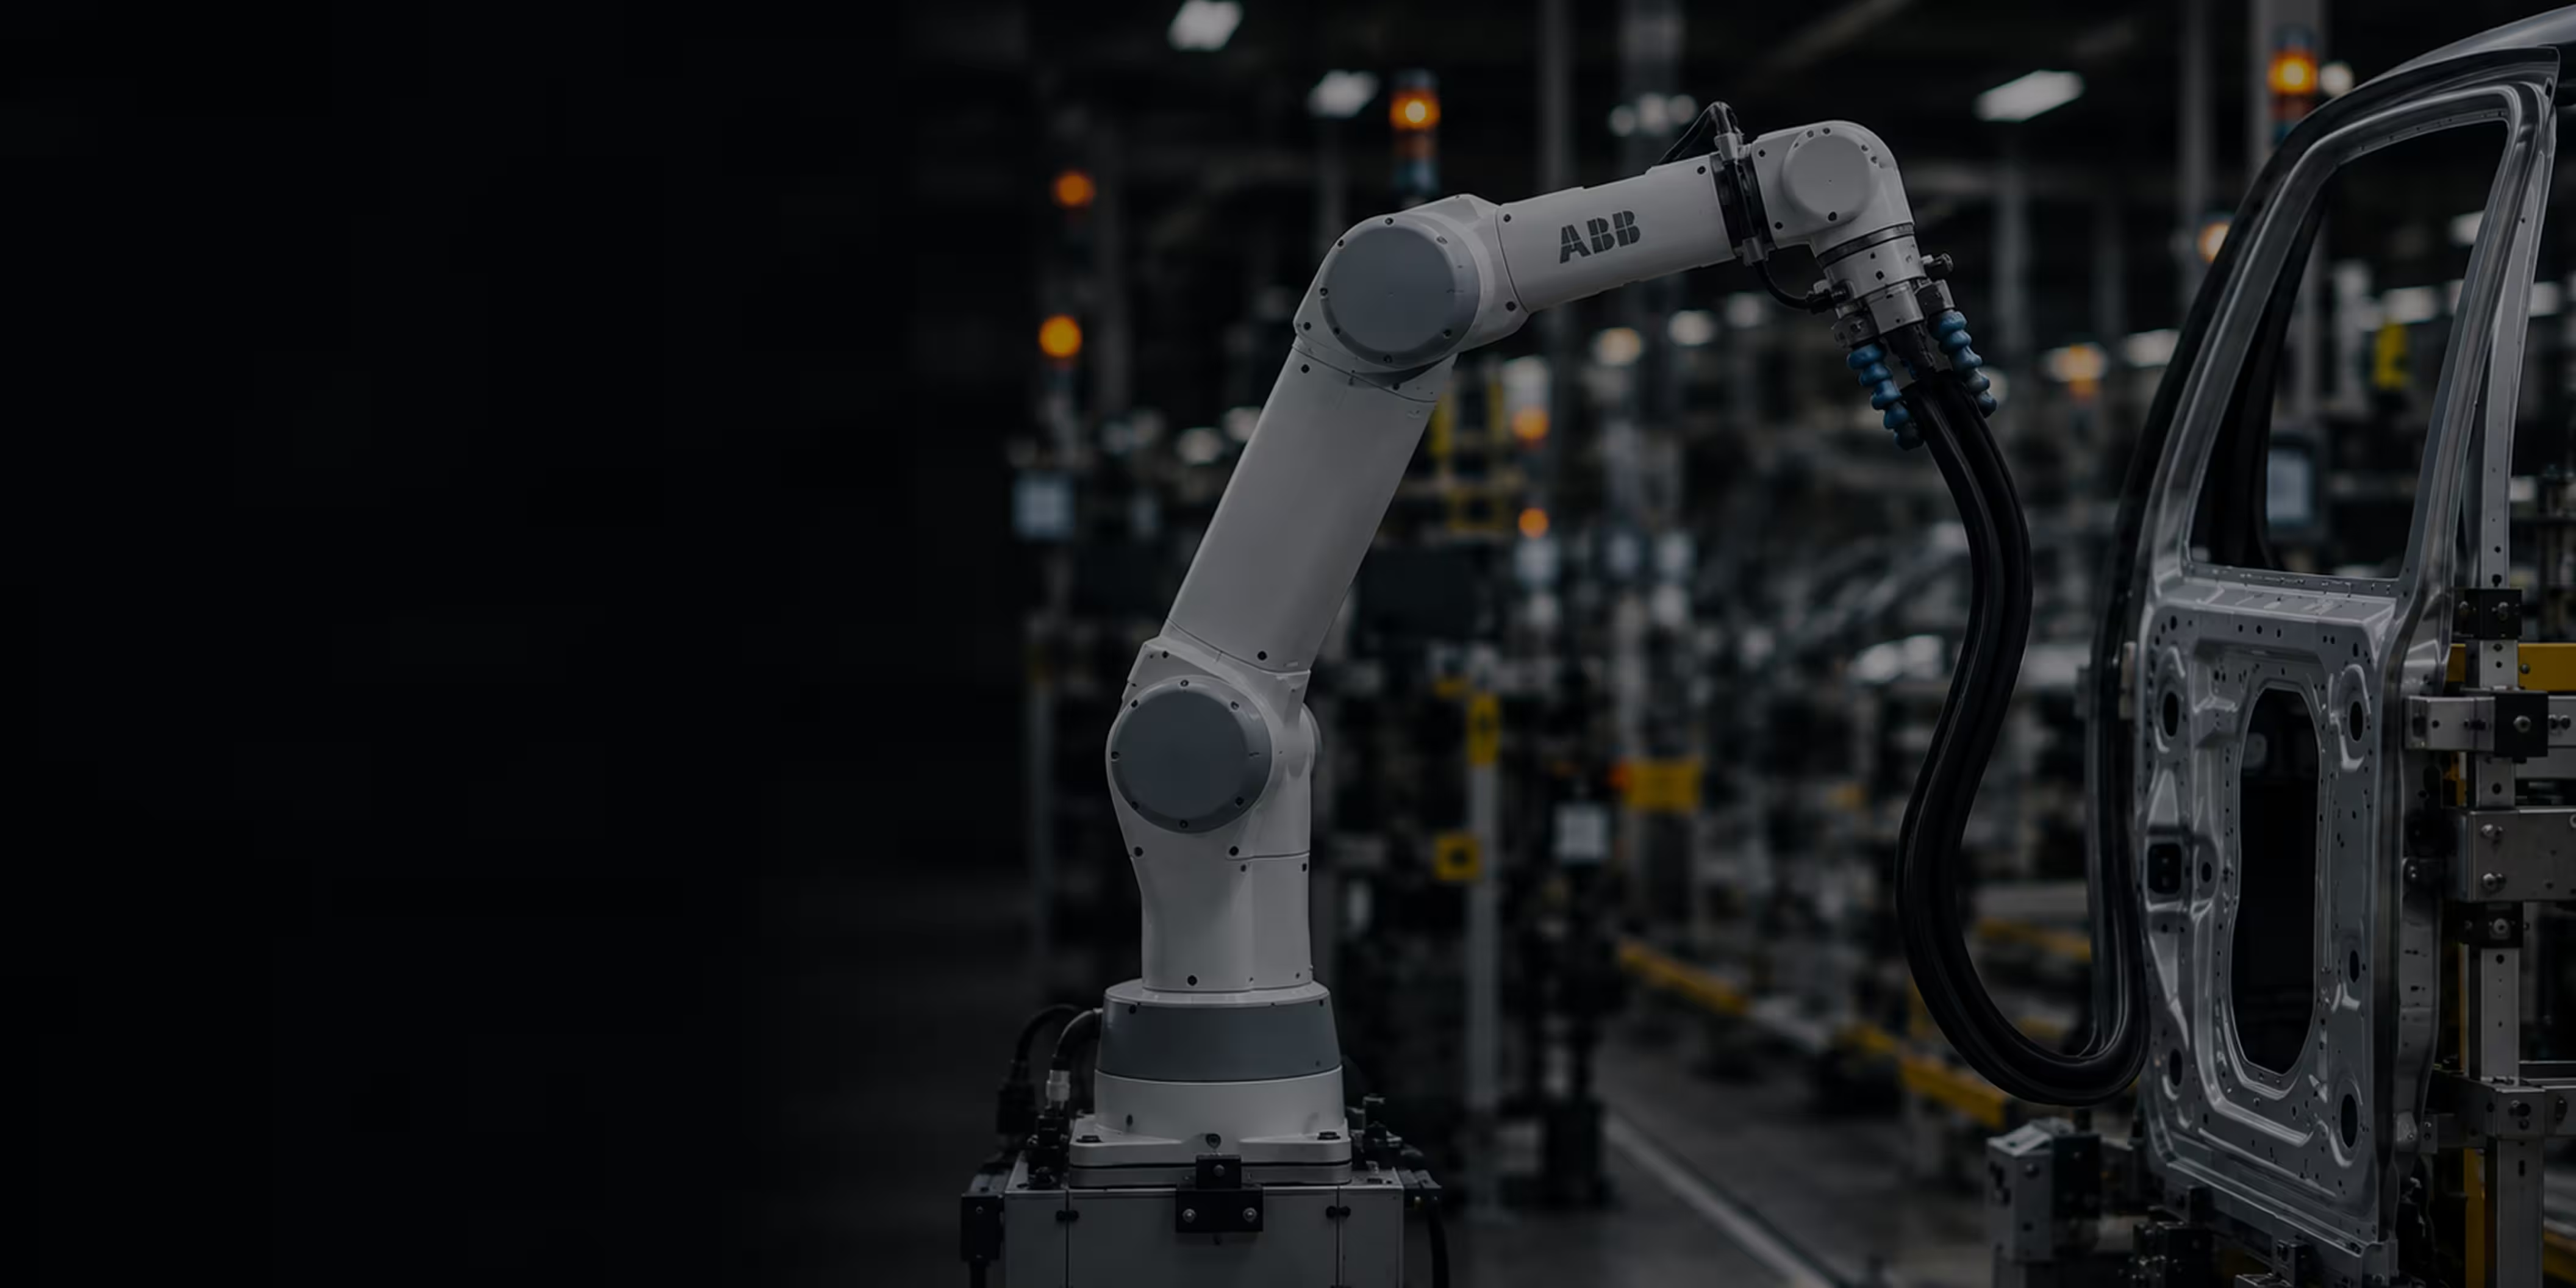


What it does
The hard part
01
Parts behave unpredictably
A flexible part has effectively unlimited degrees of freedom. The model predicts sensation instead.
02
Parts deform with every touch
Model instinctively adjusts grip, angle, and force in response to subtle tactile cues.
03
Parts vary with constraints
Parts deform, tolerances stack, environments shift, and yet the task is completed reliably.
Multimodal
Vision, Motion, Torque, Lidar
150Kb-350Kb
Avg Model Size
95%+
Zero-Shot Completion Accuracy
Thank you! Your submission has been received!
Oops! Something went wrong while submitting the form.